How Solbit responds.
I designed the experience architecture across the robot, parent portal, and teacher workflows, including the projected expressions and interaction states that supported children’s conversations with Solbit.
Designing a voice-first learning companion through projected light, conversation, and movement.
FROM EARLY PROTOTYPES TO A CONNECTED LEARNING EXPERIENCEMeet Solbit HUMAN–AI INTERACTION / CHINA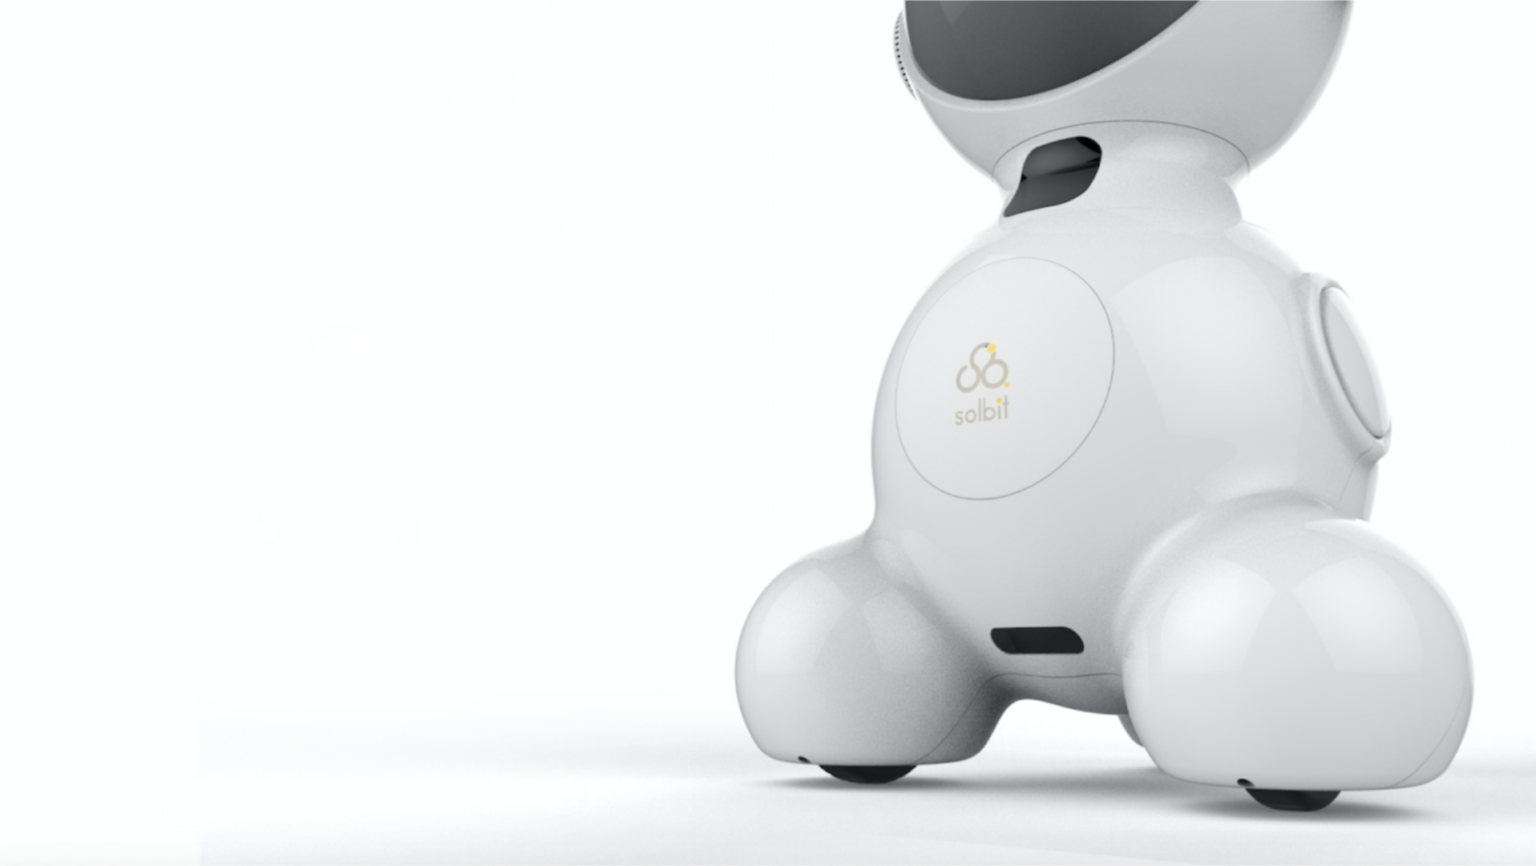
A quiet circle. Ready to listen.
DRAG TO ROTATE · EXPRESSION STUDIES
As the sole in-house designer, I connected Solbit’s product experience, physical design, brand, and communication.
I worked closely with a freelance industrial designer, the CTO, content writers, and translators to bring the product and its story together.
I designed the experience architecture across the robot, parent portal, and teacher workflows, including the projected expressions and interaction states that supported children’s conversations with Solbit.
I collaborated closely with a freelance industrial designer on product design decisions and CMF—colour, material, and finish—ideas. I also worked on 3D-printing the initial prototypes to explore the physical product.
I designed Solbit’s branding and marketing materials, extending the product’s identity across the touchpoints used to introduce it to different audiences.
I designed pitch decks and investor materials, working closely with the CTO, content writers, and translators to shape the designs and communicate the product story.
We wanted children to interact with a companion through conversation, movement, and curiosity.
Solbit was an educational robot designed for children in China, including those growing up without siblings. It could recognise objects, respond to basic maths questions, move around the home, and return to its charging dock.
Its role was to support early learning alongside teachers and parents. The challenge was to make the robot’s responses understandable without a touchscreen.
A glowing teal circle became Solbit’s visual vocabulary.
A projected human face would have tied the experience to human expressions. A circle gave us room to communicate through shape, colour, and movement: a nod, a shift of attention, a light bulb, or a mathematical symbol.
I designed the interaction states and their animations so that the robot’s voice and visual feedback worked together.
“We kept one glowing teal circle, then changed its shape and colour to respond to the question.”— My interaction design approach
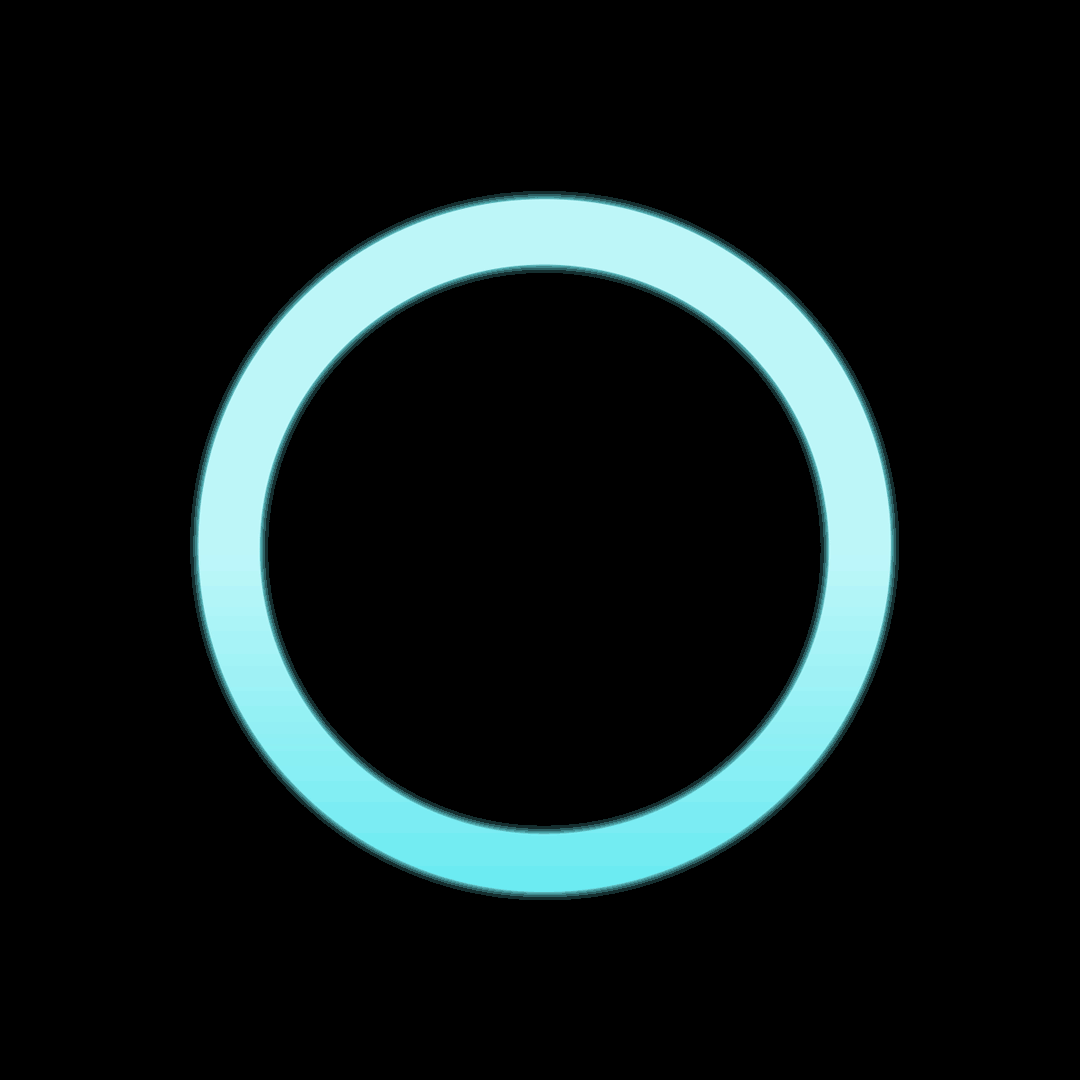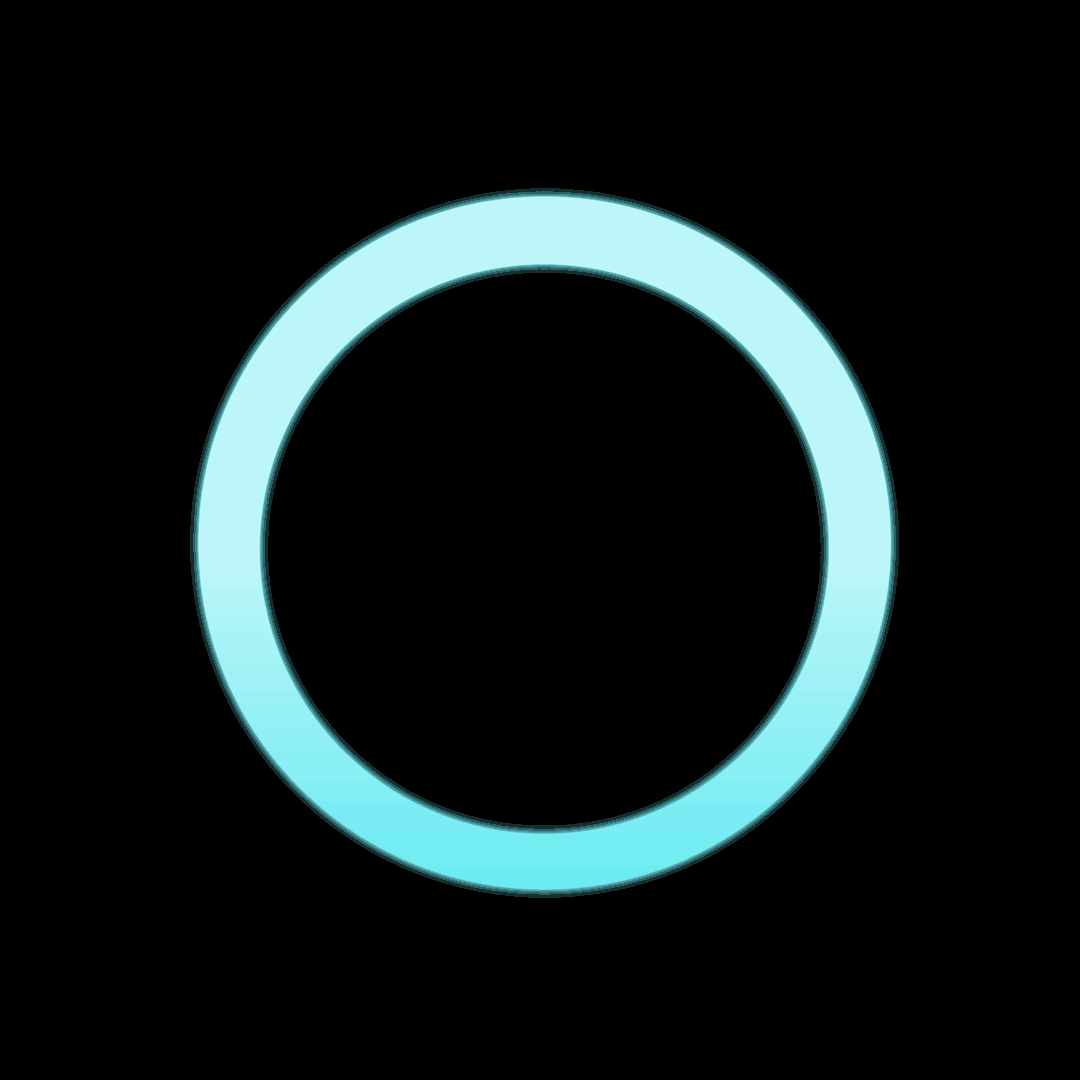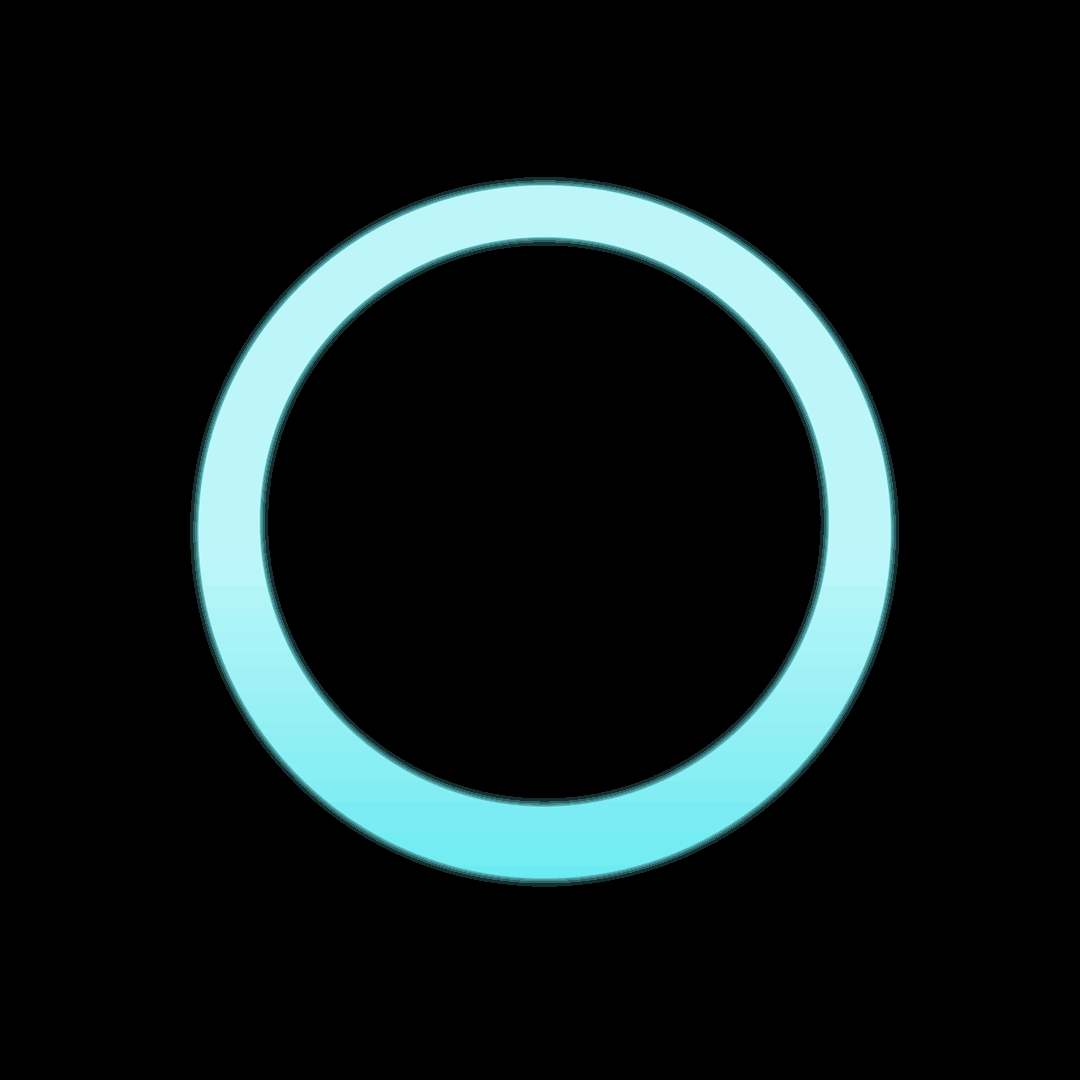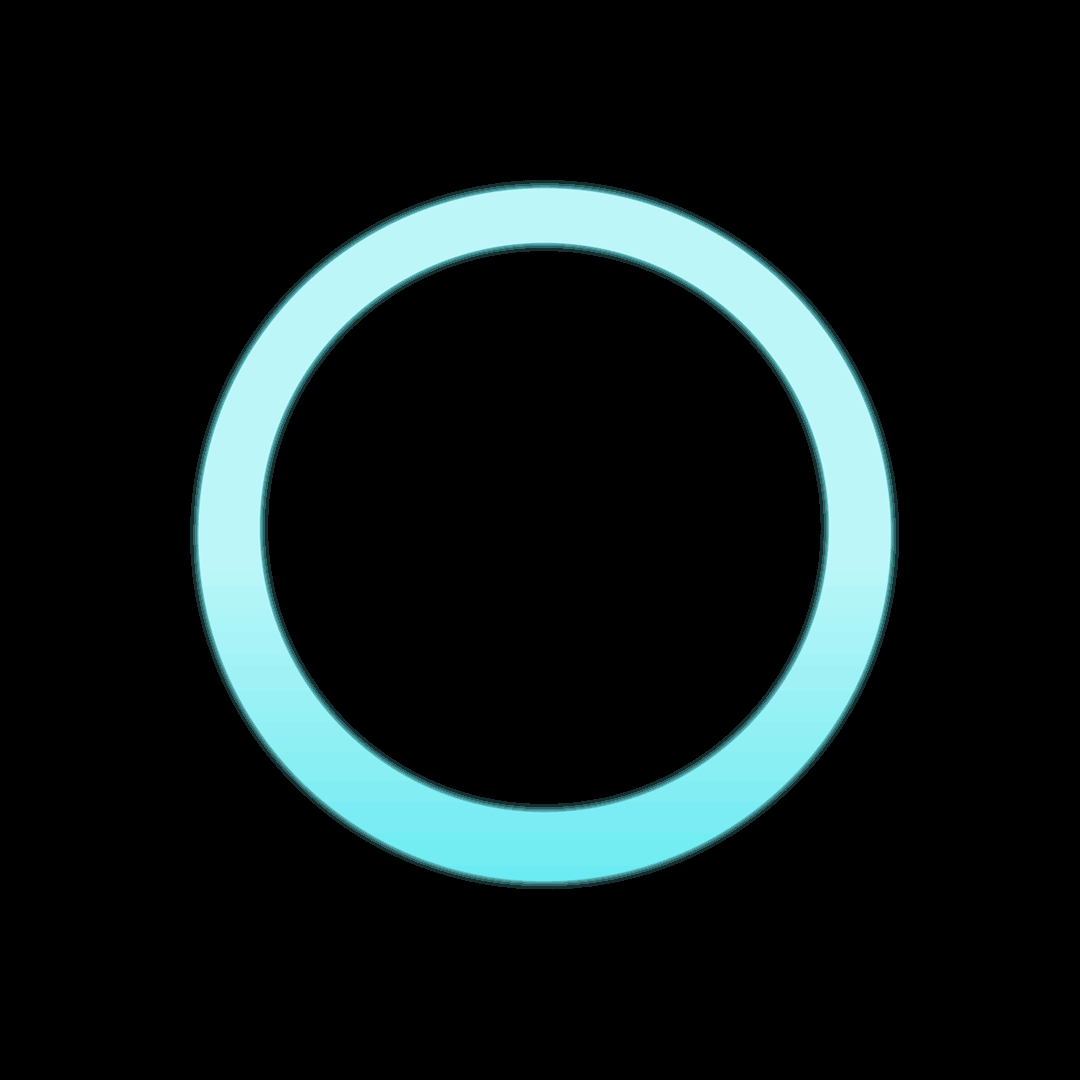
Original interaction animations. Directional feedback used input from four microphones around the head.
Explore how one circle can communicate different meanings. Choose a prompt to see a response.
A quiet circle signals that Solbit is ready to interact.
Interactive recreations made for this portfolio. The maths, science, question-mark and fruit examples illustrate the visual language; original GIFs are shown above. No live AI or microphone access.
A practical need, expressed in language a child could understand.
When its battery ran low, Solbit would explain that it needed rest, then return to its charging dock. The words, animation, and movement helped make the transition from play to charging understandable.
Ready for one more question?
Illustrative motion study of the described return-to-charge experience.
The child’s interaction was one part of a connected learning experience.
I designed the experience architecture across the robot, the parent portal, and teacher workflows. The goal was to connect lesson creation, parental oversight, and the child’s learning in one understandable journey.
Upload lesson documents and update learning content.
Review lessons, send them to Solbit, and follow the child’s interactions.
Ask questions, show objects, and explore lessons through conversation.
Review information that needs attention and guide the next learning moment.
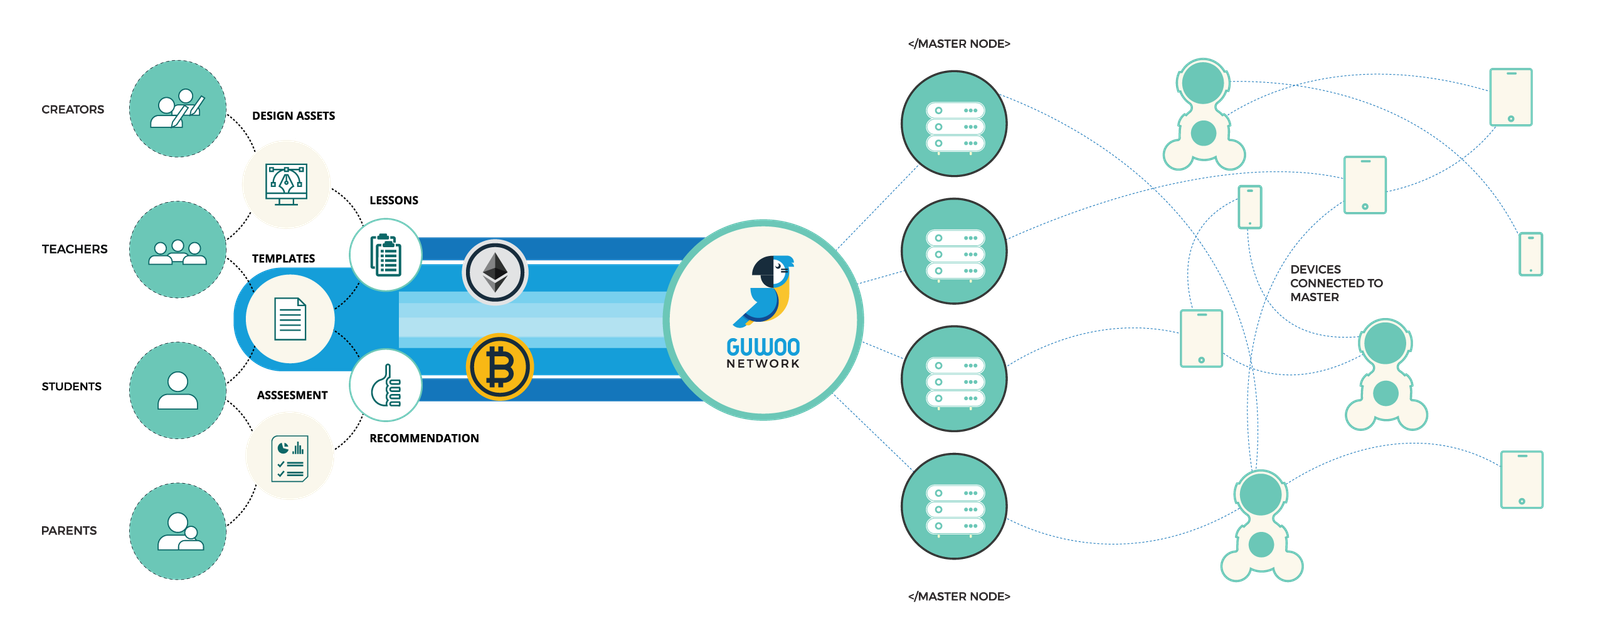
Original project architecture illustration, with an illustrative animated walkthrough. Moving signals explain the experience flow; they do not represent live data. Swipe across to explore the complete diagram.
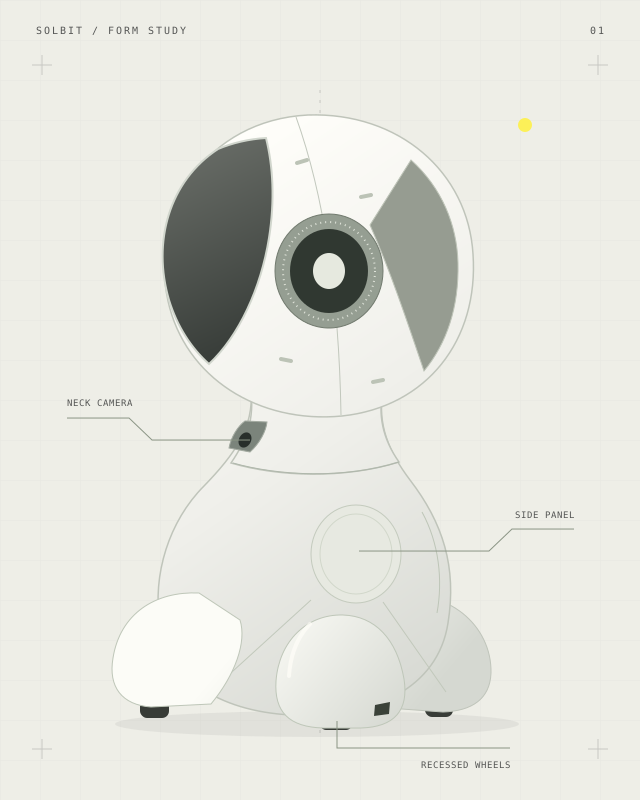 VECTOR STUDY / SIDE PROFILE
The vector study and interactive 3D model are approximations reconstructed from project photos, not production CAD. Sensor locations beyond those confirmed are not labelled.
Early prototypes went into classrooms around Shenzhen and Nanjing, with teachers involved in the sessions.
Children initially touched the robot’s face. Once Solbit began speaking and projecting responses, they started interacting through conversation. When the roughly 25-minute prototype session ended, children asked to keep playing.
This was an encouraging qualitative observation from early trials. It was a starting point for further development, rather than a measure of long-term learning outcomes.
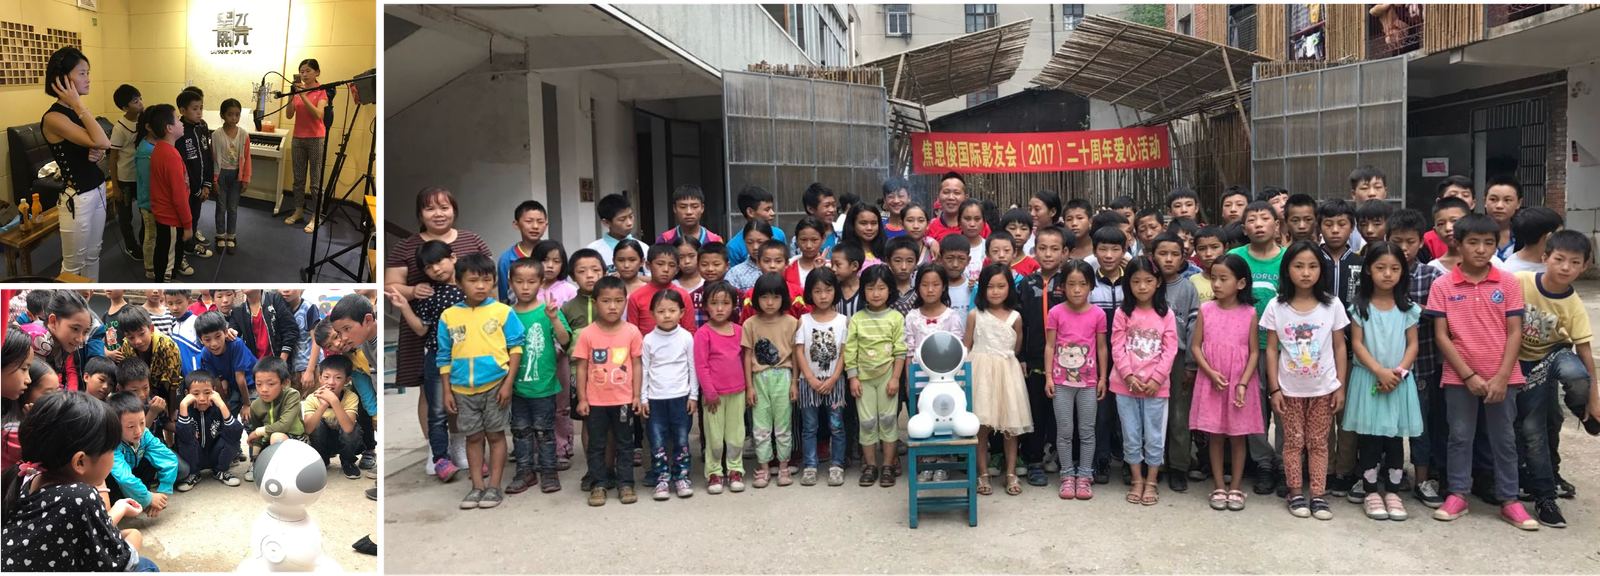
These project photographs show children and adults in a recording setting and children gathered around Solbit.
They add context to the early project work alongside the trial observations described here.
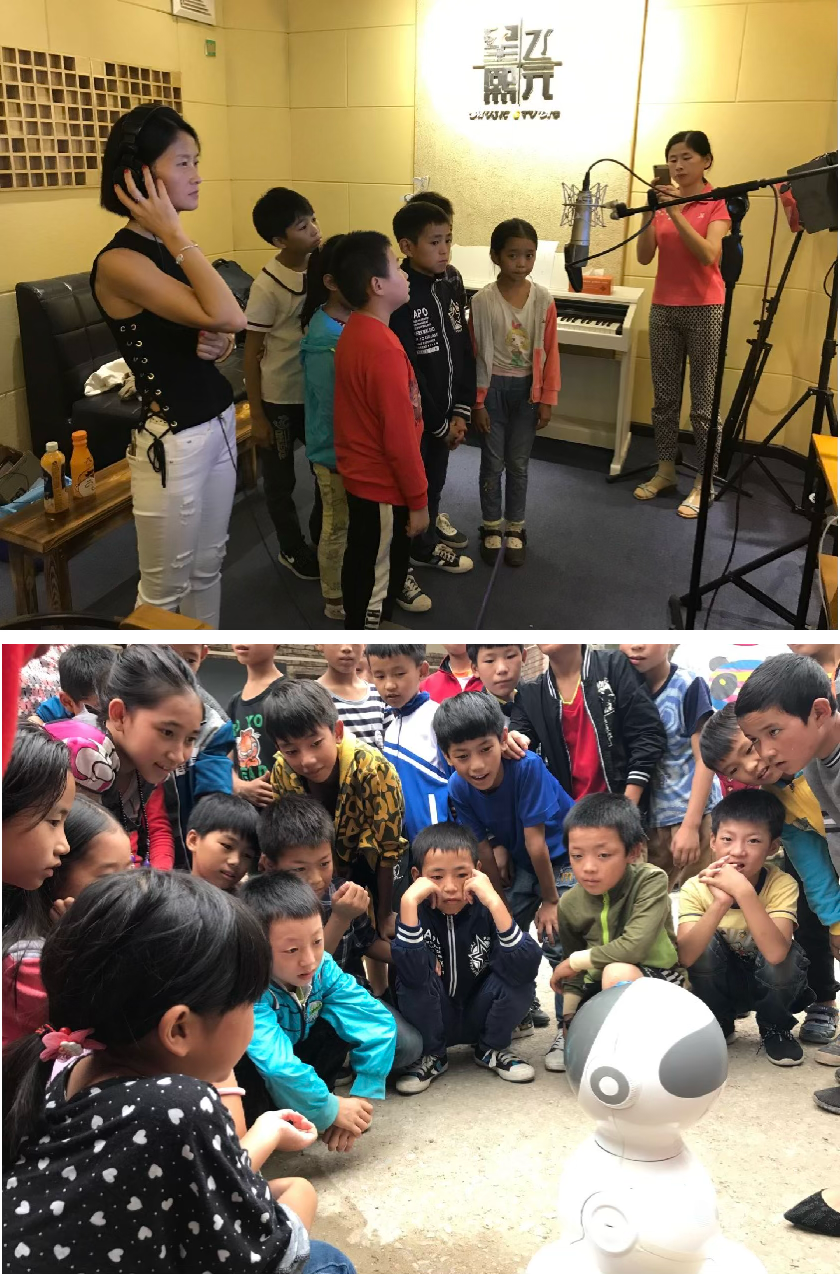
Children explored the unfamiliar form through touch before discovering its spoken and animated responses.
Battery life limited early sessions. Teacher feedback informed plans for additional sensing, including side and rear cameras and more microphones.
Attention, answers, uncertainty, and the need to recharge all deserve clear feedback—not just a successful response.
Trial observations and project history are based on my account. Additional sensors were proposed improvements, not features confirmed on the initial model.
Solbit shaped the way I think about AI experiences: make the system’s state visible, give uncertainty a language, and design the whole journey around the people involved.
Those questions still guide my work today.
Explore TCL Smart TV